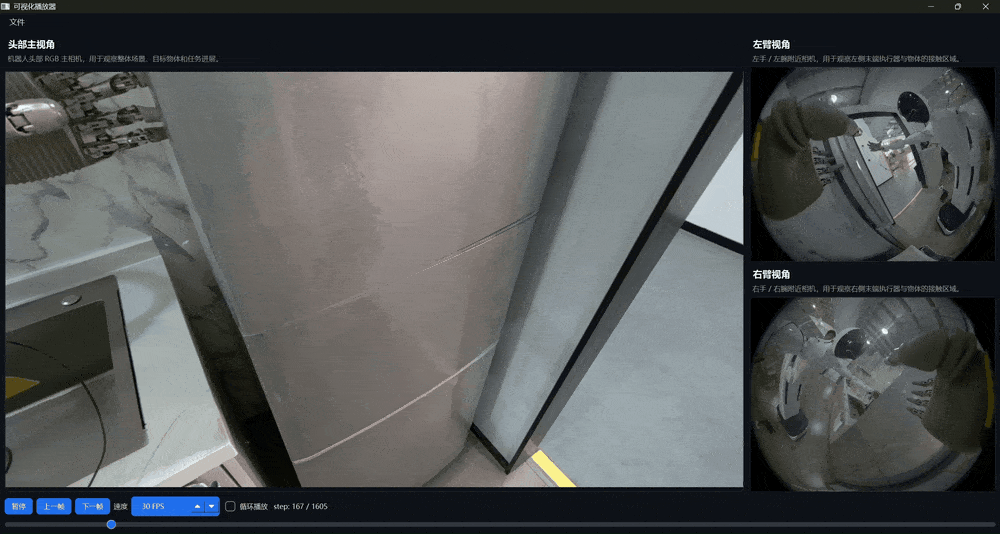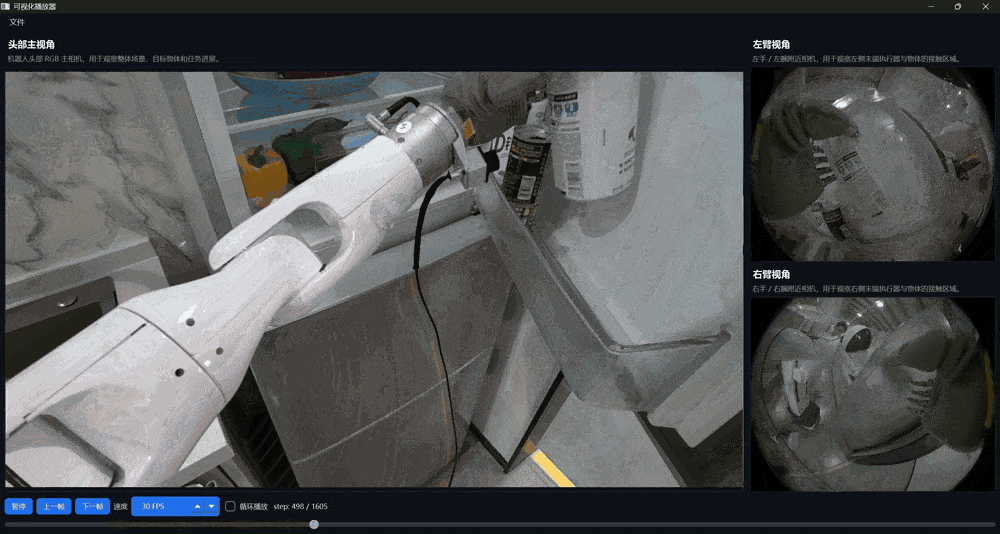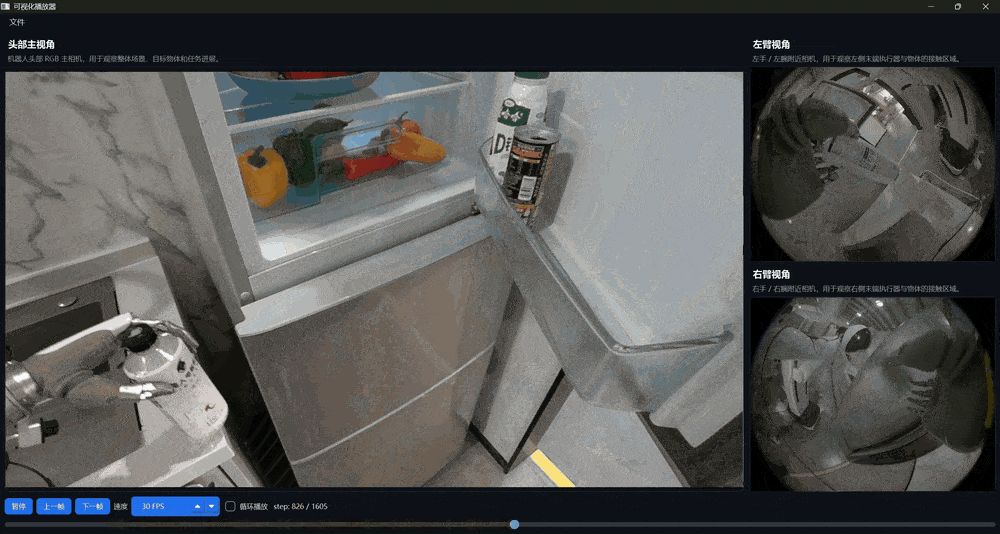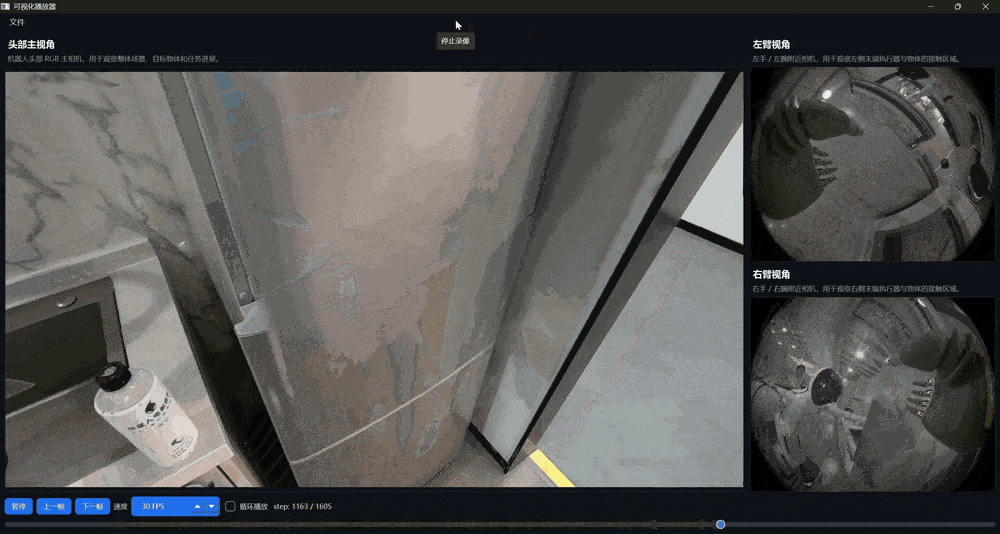
01–05
06–10
11–15
16–20
21–21
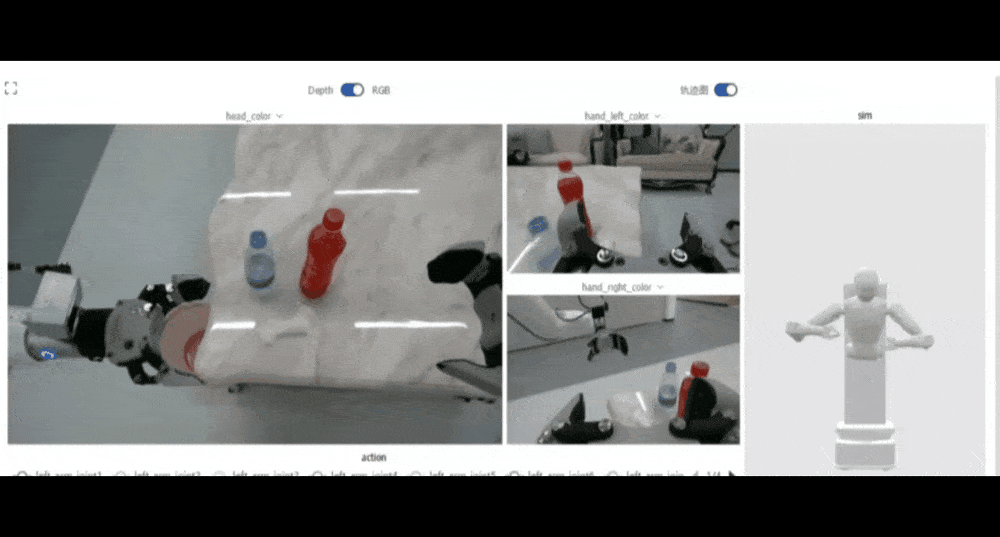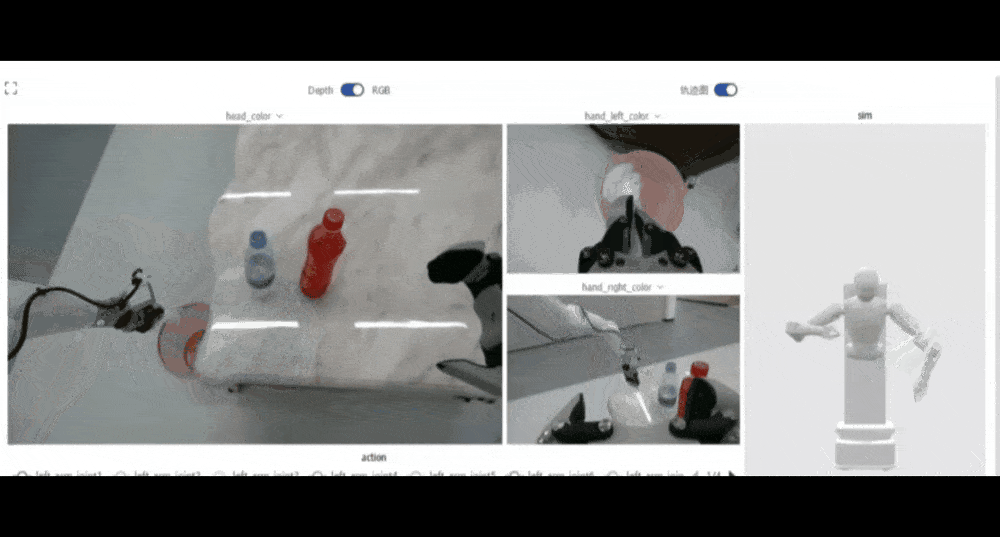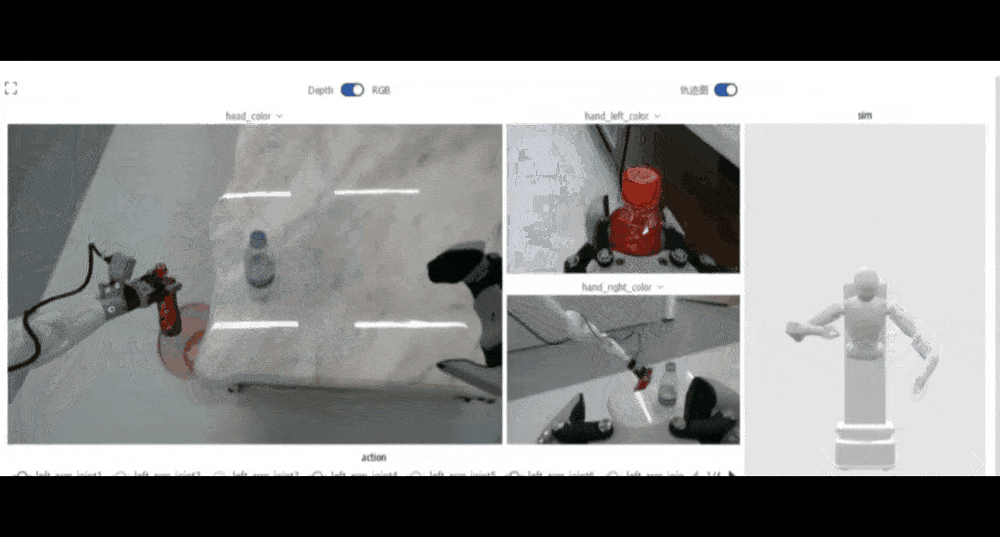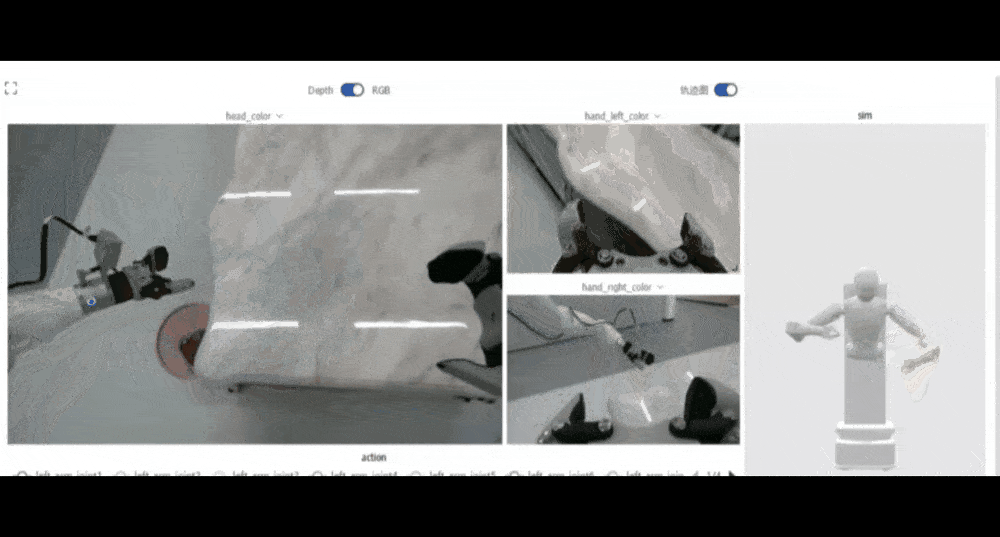
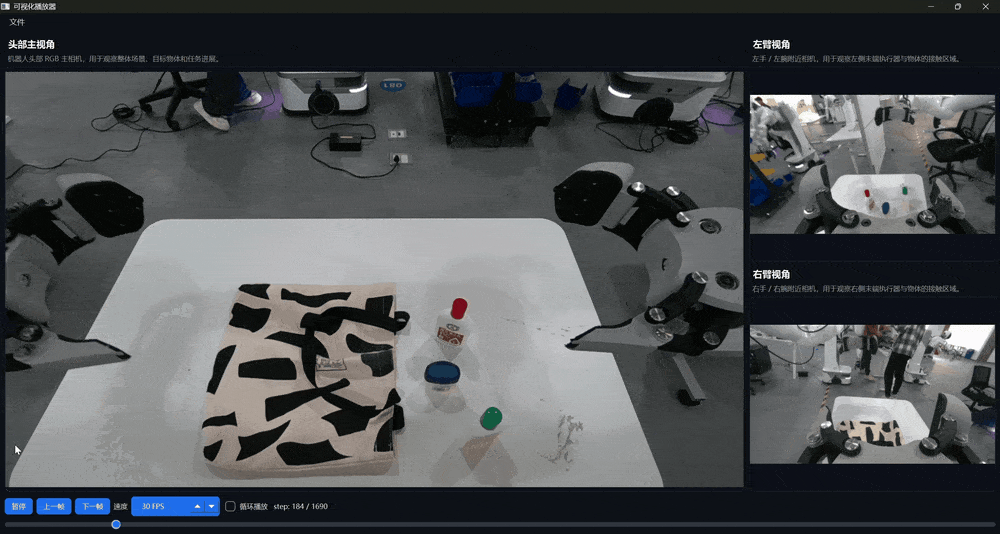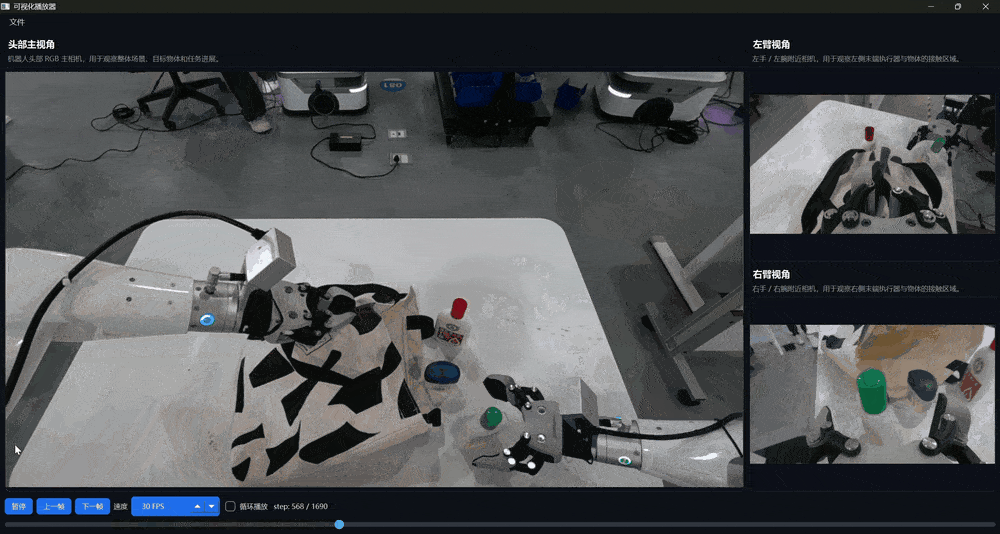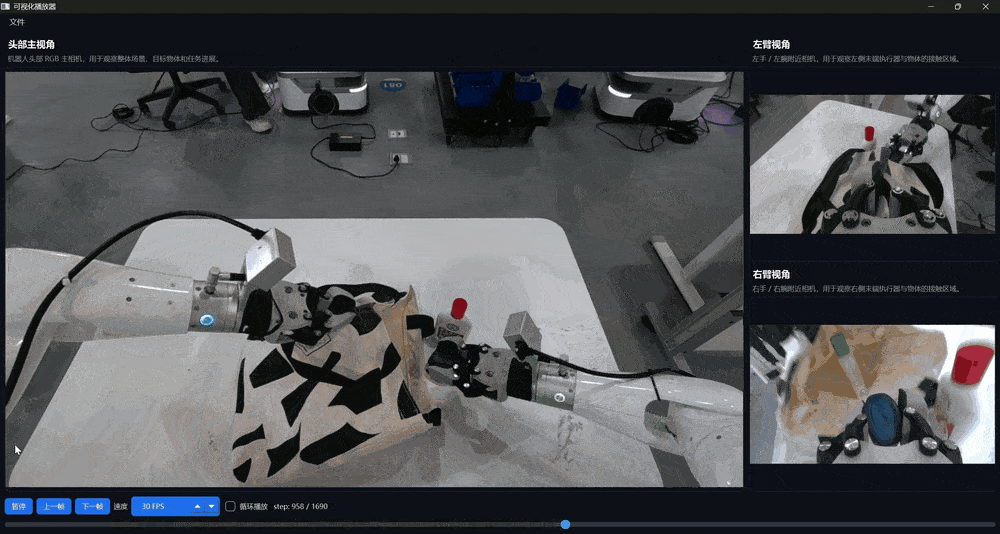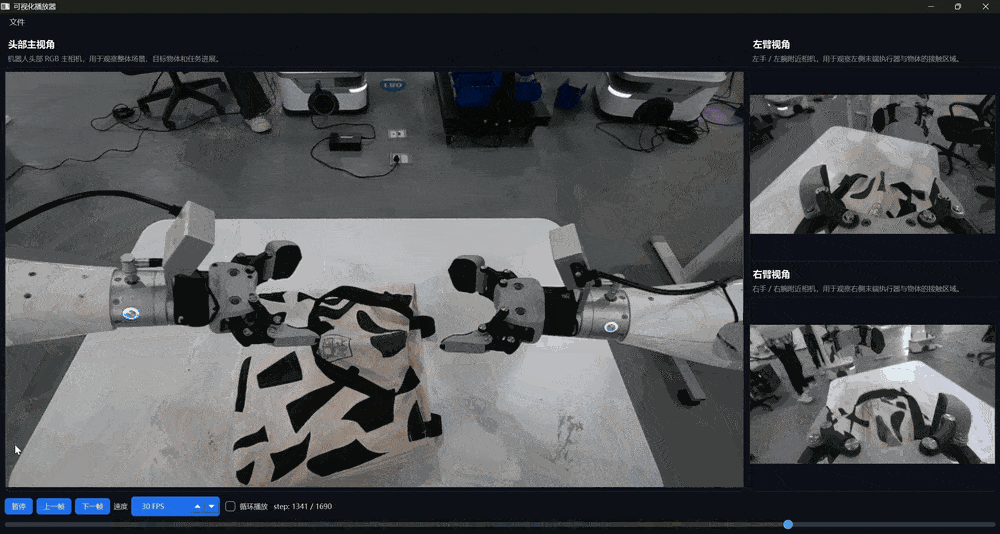
Object recognition, grasp poses, end-effector trajectories and outcome feedback.