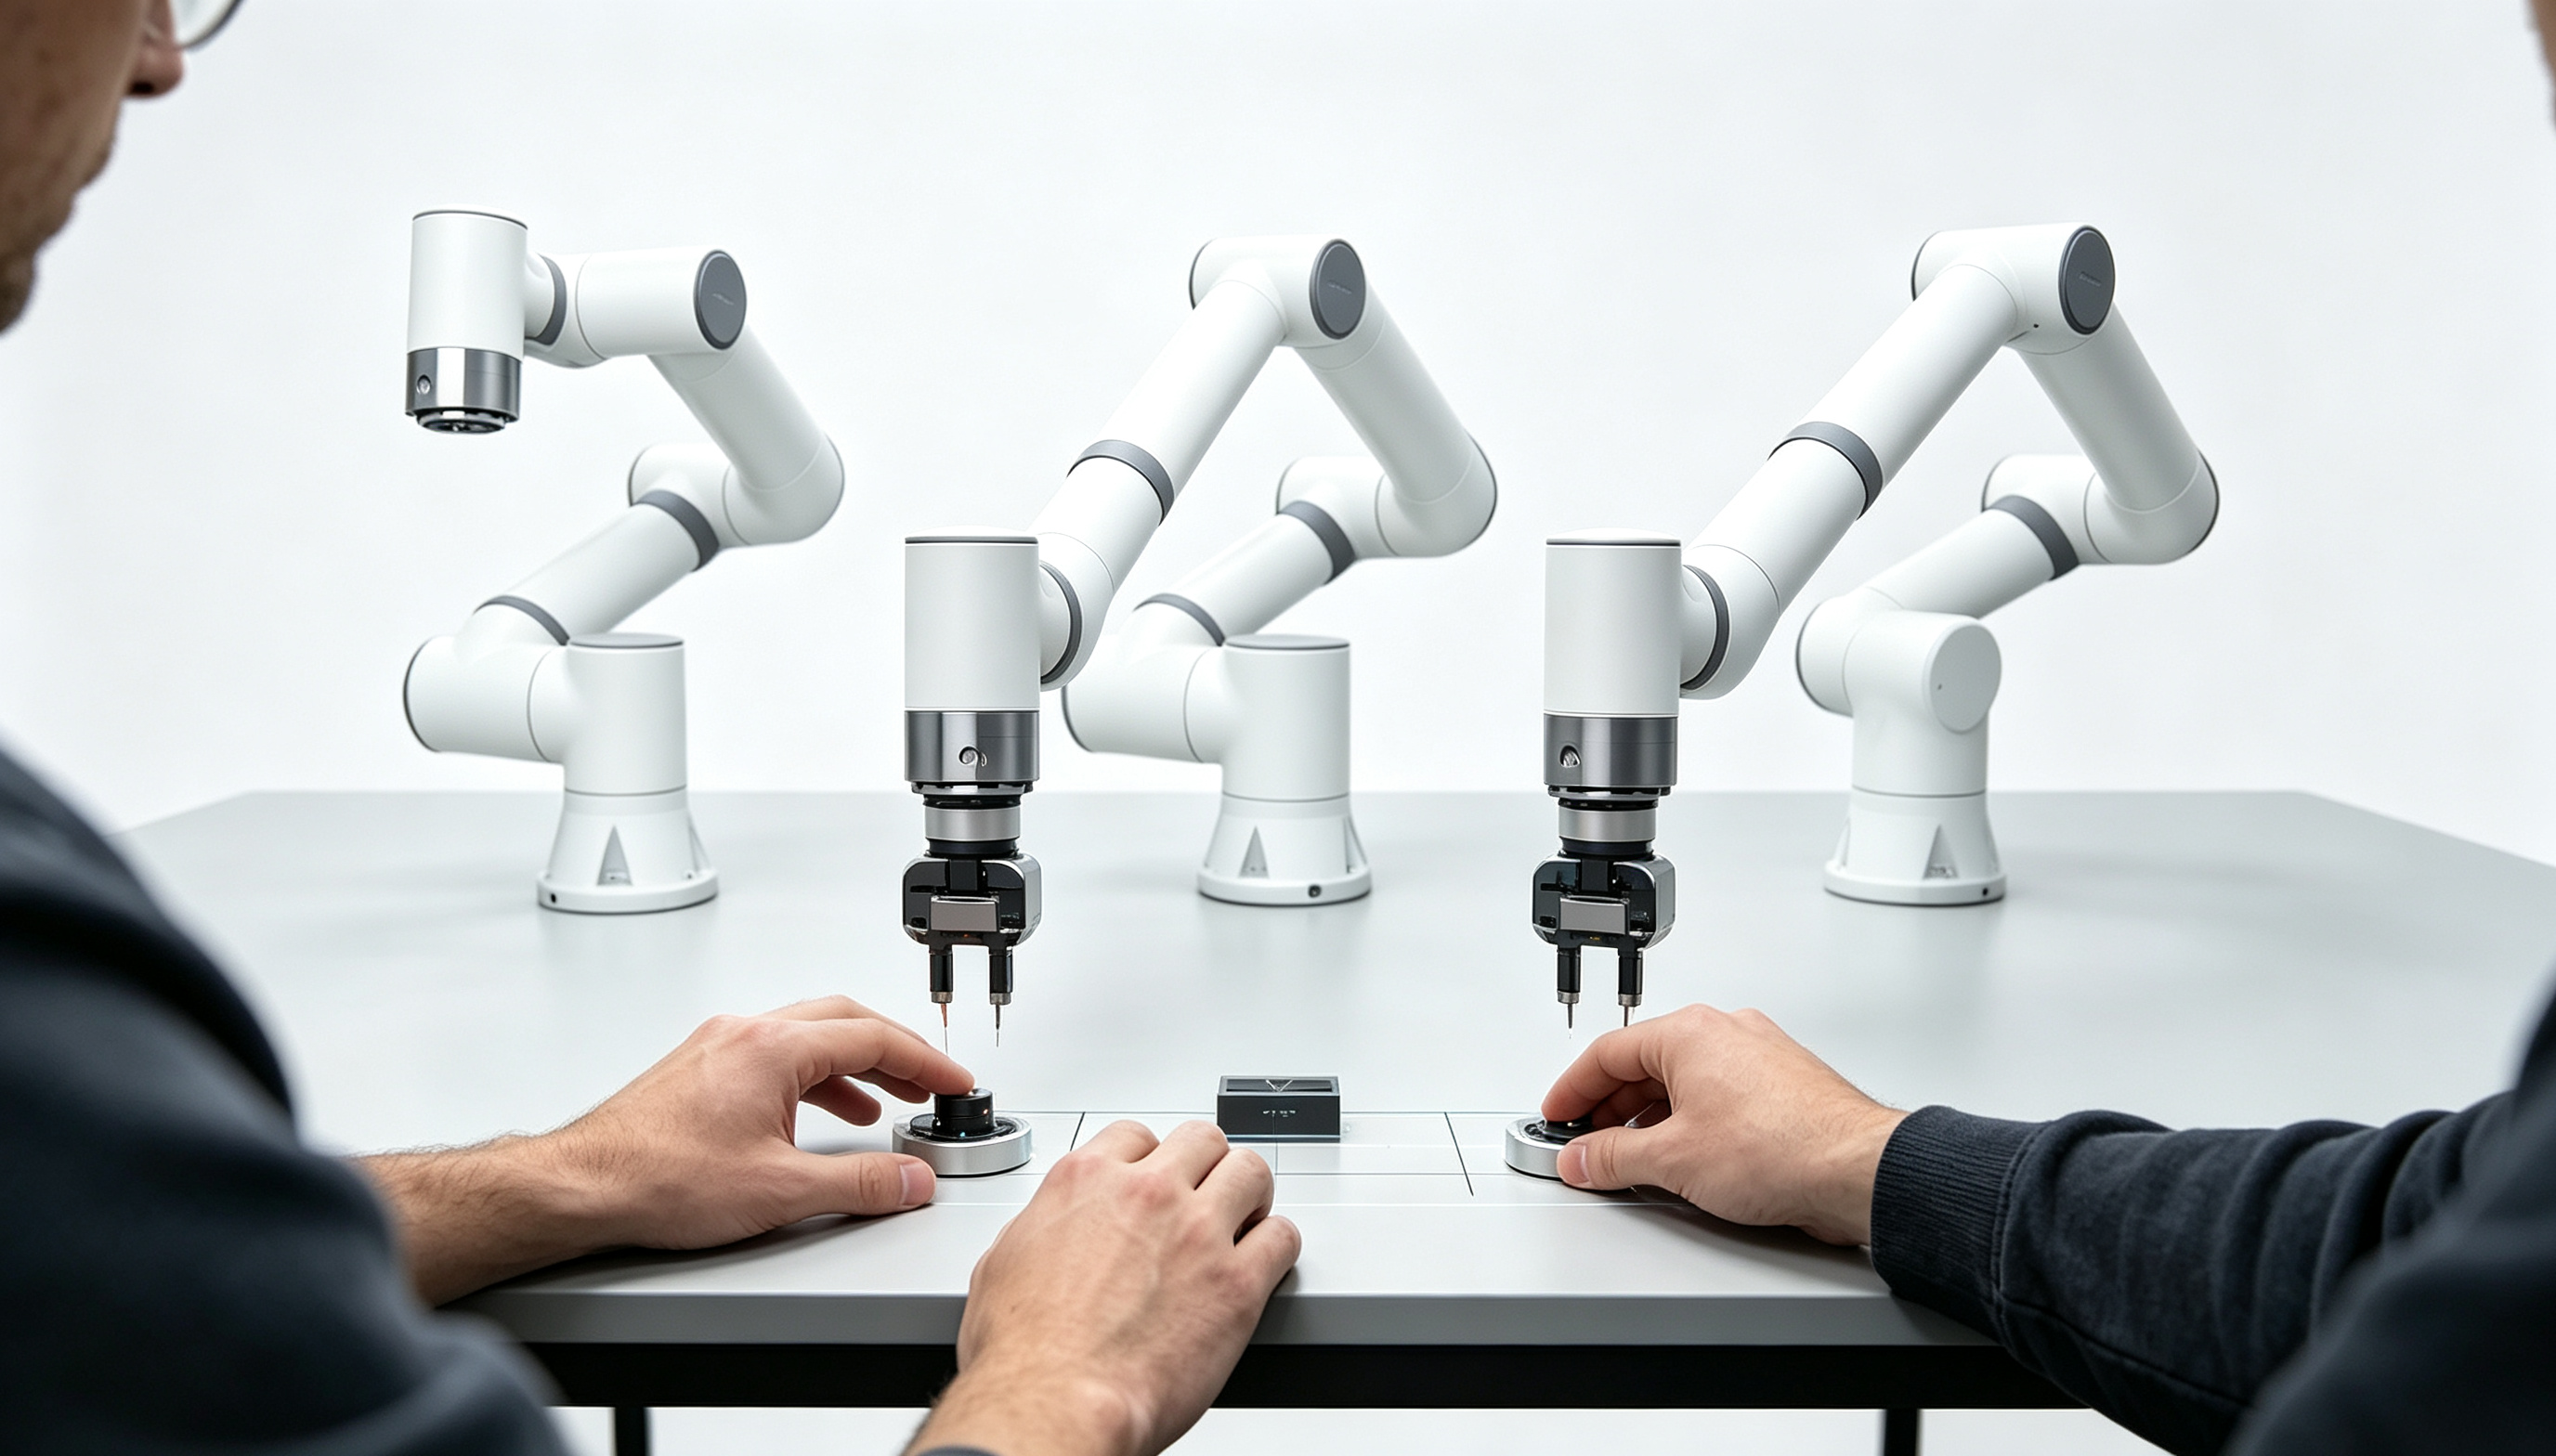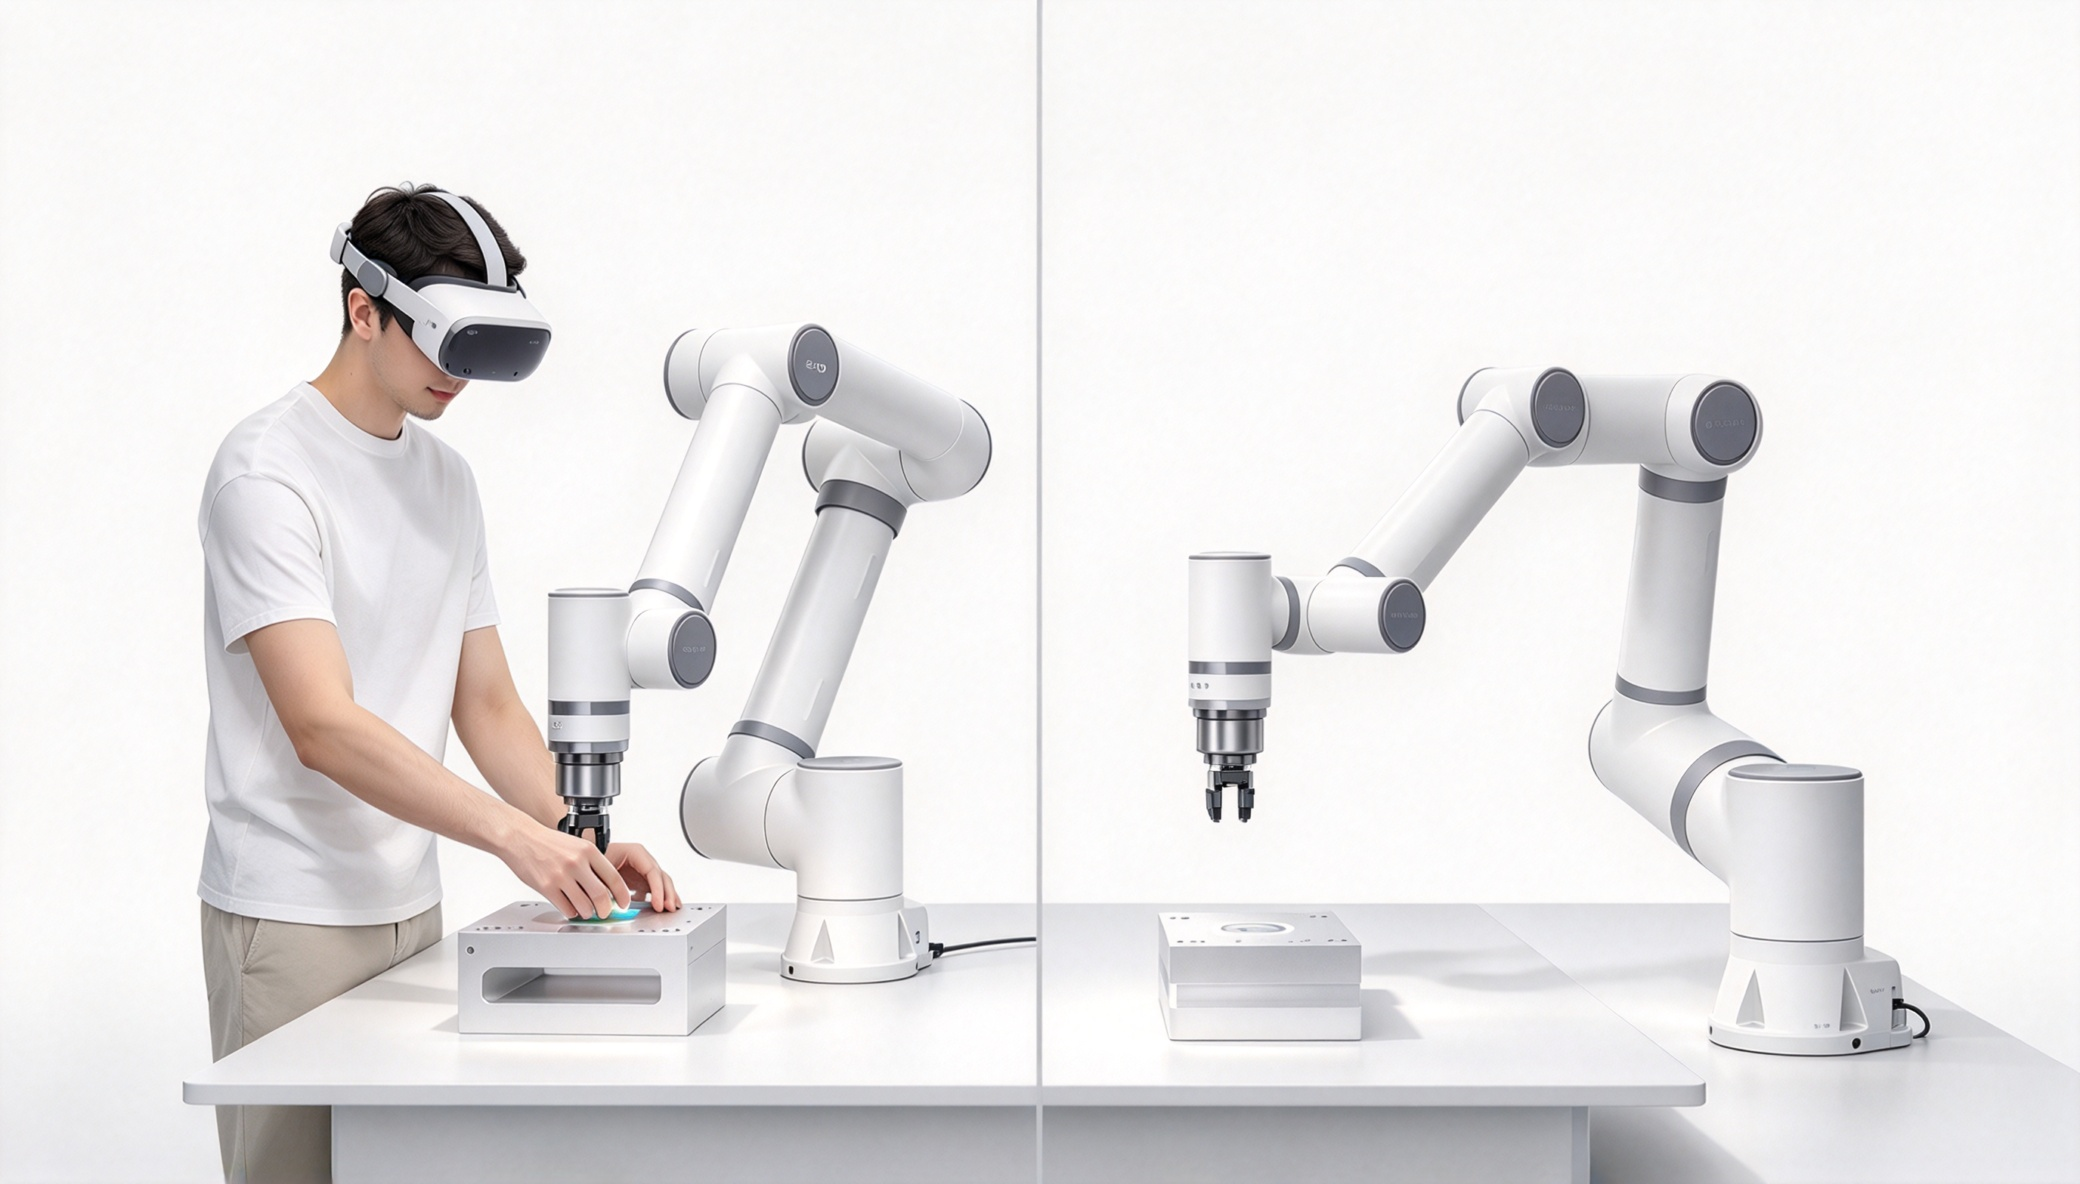
Multi-Modal Capture多模态采集
01 / VISUAL FEED03 frames
Drag or select a thumbnail to browse
DEVICE DETAILLEVEL 04
DEVICE / PROFILE
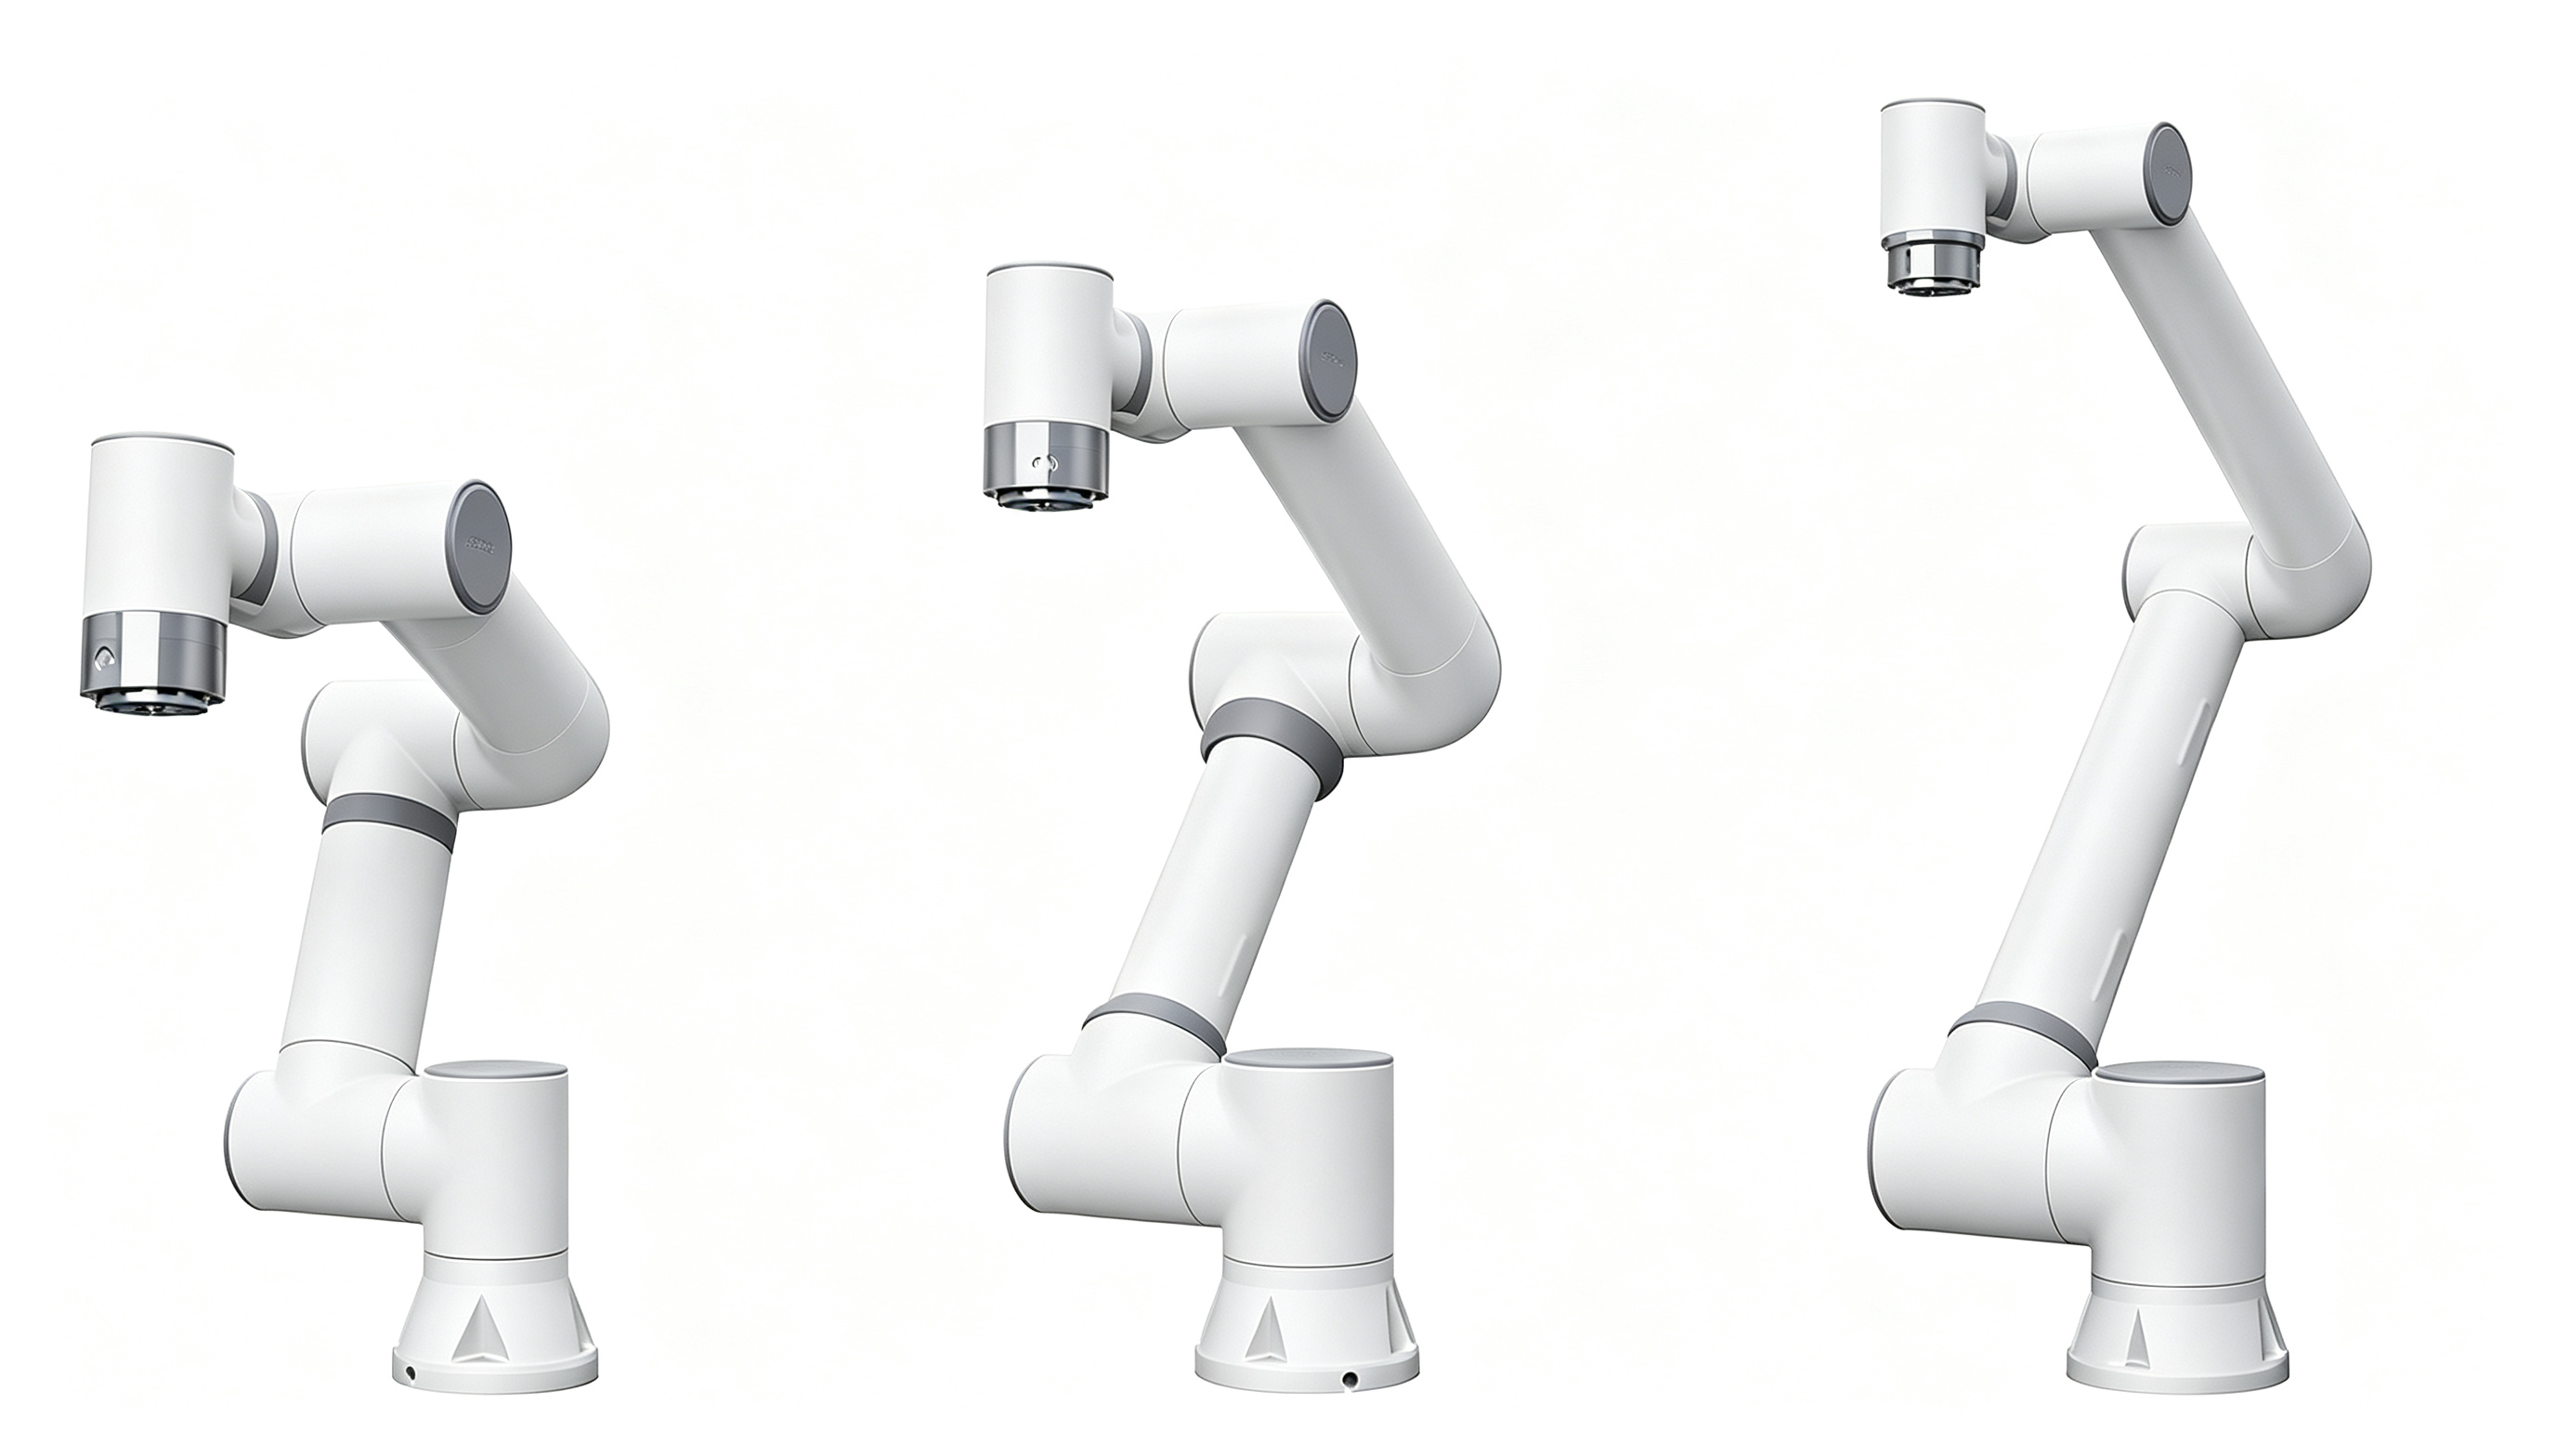
Multi 6-Axis Collaborative Robot Arm Platform
Multi 6-Axis Collaborative Robot Arm Platform
- Vendor
- detail future
- Model
- DF-MC6-2
- Device code
- DF-MC62-20260901
PROFILE ID h-ac87b4ed6d26
CAPTURE CHANNELS05core channels
TECHNICAL GROUPS06data groups
PROFILE STATUSACTIVEcurrent device entry
Core capture capabilities
Device capability matrixCapture pipeline and device capability overview
5 capabilities多六轴协作机械臂协同采集平台Multi 6-Axis Collaborative Robot Arm Platform
Binocular Vision双目视觉
Embodied AI Data具身智能数据
Egocentric Capture人视角采集
Motion Sensing运动感知
Core technical parameters
Basic Information基础信息
- Device Name
- Multi 6-Axis Collaborative Robot Arm Platform
- Manufacturer
- detail future
- Model
- DF-MC6-2
Physical & Hardware物理与硬件参数
- Dimensions
- Base Platform:1800×1200mm;Single Arm Reach 1300mm
- Weight
- Total ~110kg (34kg per arm ×2)
- Battery Life
- External DC power supply, no built-in battery
- Storage
- Central controller built-in 64GB
- Operating Temp
- 0 ~ 45 ℃
Output Data Types输出数据类型
- RGB Image
- Synchronized RGB streams from multi-arm end cameras
- Depth
- Synchronized depth streams from end depth cameras
- Point Cloud
- Real-time point cloud generated from multi depth streams
- IMU
- Built-in joint IMU on each robot arm
- Audio
- Optional, multi-microphone synchronous audio
- Pose
- Synchronized TCP cartesian pose of all arms
- Joint Data
- Joint angle, velocity, torque of all robot arms
Camera Parameters相机参数
- Resolution
- 1280×720 / 1920×1080, multi-stream sync
- Frame Rate
- 30fps, hardware sync for all cameras
- FOV
- Horizontal 84°
- Sensor
- CMOS
- Exposure
- Auto / Manual adjustable, exposure sync
IMU ParametersIMU参数
- DoF
- 6-axis IMU per arm (3-axis accel + 3-axis gyro)
- Accel Range
- ±16g
- Gyro Range
- ±2000°/s
- Sample Rate
- 1000Hz, time-synchronized across all arms
Interface & Communication接口与通信参数
- Interface
- RJ45 Gigabit Ethernet, multi-channel Digital IO
- Protocol
- TCP/IP, Modbus, ROS2, real-time sync bus
- Power
- DC 24V, independent power loop for each arm
- Bandwidth
- 1000Mbps, support multi-sensor high-volume data stream
Applicable capture scenarios